

Truly dexterous manipulation
Santa Clara
Joined September 2025
- Tweets104
- Following24
- Followers1.4K
- Likes115
Pinned Tweet
What if the answer to dexterous manipulation has been in the human hand all along?
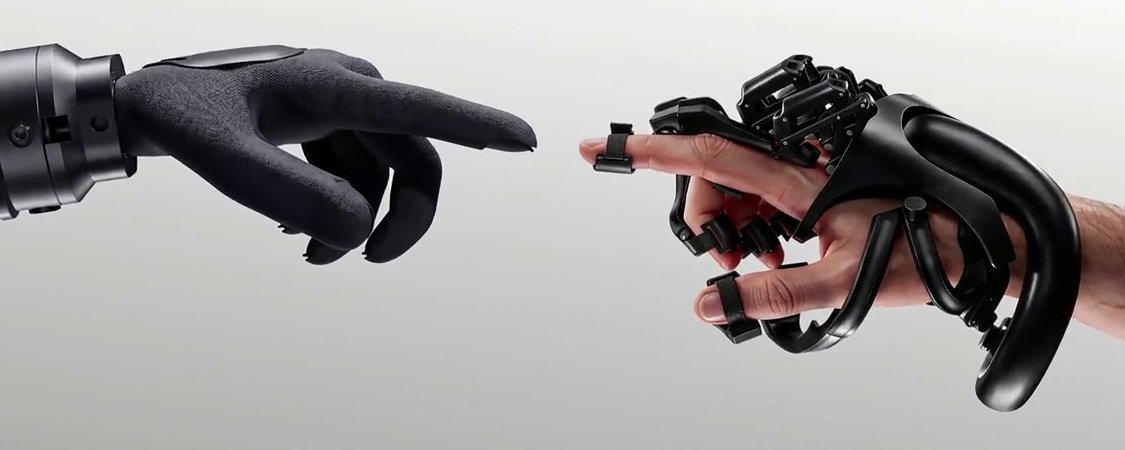
Aero UMI and Aero Hand: 100% co-designed.
Same structure, same contact surfaces, same sense of touch.
IROS 2026, Booth 842, from Sept 28. We'll show you.
A robot learns best from a hand built exactly like its own.
NVIDIA’s GR00T 2 whitepaper, in one sentence:
“Because the exoskeleton replicates the hand, no robot play data are needed.”
That’s Aero System: two hands designed as one, matched 100%.
After our business card demo, a few of you asked: “Okay, but is it real? How do we know you’re not faking it?”
Fair question. Watch the grip, then watch the tactile data.
Here’s what a firm vs. gentle pinch looks like beyond the video. 👇
#AeroInAction
Got Hands? Ep. 05: Monday grip ☕️.
Back at work. Need coffee. Taking it out on the cup. Watch Aero UMI + Aero Hand squeeze a cup under teleoperation. With deformable objects, how hard you grip matters.
How’s your Monday going?
#AeroInAction
Thank you all for the support and feedback. Time to put our heads down to work harder.
So much to do.

We brought Aero UMI to #CoRL, presented at UMI Arena (umi-arena.airoa.io), and joined the competition. A few takeaways from the week:
1. The data recipe matters as much as the hours. Conversations left me more interested in how human video, precise motion, tactile data, and robot experience work together.
2. Standalone collection is valuable. Connecting it to a robot adds more value. Replay, validation, and training help us understand what the data teaches—and what to collect next.
3. Data filtering and evaluation belong closer together. If we can judge demonstration trajectories, some of that logic should help evaluate policy behavior. Could judgments at each step also help us learn a better critic?
4. As agents automate the tools, the feedback loop matters more. I’m excited about using real robot failures to guide what we collect, simulate, and test next.
5. Hardware consistency is a data-scaling advantage. Calibration, repeatability, and reliability matter when combining data across devices, people, and days. Hardware and learning pipelines should be designed together.
Thanks to the UMI Arena organizers @ohtake_i , everyone who exchanged ideas with us, and our team
@ChestnutRobotic . Lots to bring back to the lab.
#CoRL2026 #UMI


2
317
On our flight home from Austin with new ideas, new friends, and a lot of handshakes. Thank you, @corl_conf , for the convos and shared curiosity. By the next handshake, we hope robots will have a better feel for the world and know when to be gentle.
Until next time, stay in touch🤝Reach out anytime [email protected]
#CoRL2026 #Robotics #DexterousManipulation #RobotLearning
Chestnut Robotics retweeted

Come to try out our aero UMI and aero hand at UMI arena at #corl @ChestnutRobotic


We’re waving you over 👋 Come meet Chestnut Robotics, see our UMI& Hand in action, and say hello!
📍JW Marriott Austin · JW 303–304
⌛Today at 2 PM
🤖 The UMI Arena #CoRL2026
Come take a closer look and if you like what you see, vote for us 🌰
Got Hands? Ep. 03: Find your match.
A little late for Singles’ Day, but here’s the goal: find someone as in sync with you as Aero Hand is with Aero UMI🤪
Matched-workspace teleoperation. Some pairs are designed for each other.
#CoRL2026 #AeroInAction
The best year is yet to come. But the best building time is here now. We cannot wait for dexterity coming itself.
Instead of worrying about LLM models wiping out the industry, we deeply believe there’s still so much dirty unsexy work to do. Don’t surrender now.

First IROS, now CoRL. Always a great conversation with Dr. Scott Walter (@GoingBallistic5), the Humanoid Botangelist himself.
Our belief at Chestnut: dexterity gets solved with high-fidelity data, tactile sensing, and a hand co-designed with both.
2027 is the year dexterous hands see real deployment.

2
6
375
Chestnut Robotics retweeted

Agree with @DrJimFan: high-quality contact data must come from an isomorphic exoskeleton. Contact kinematics have to match the robot.
The underrated part: ergonomic fit. We designed the most comfortable exo first (Aero UMI), then built Aero Hand around it.
Find me at CoRL.

Introducing GR00T 2: our most advanced, open System One model for robotics. It runs entirely on your robot’s onboard compute, fully untethered, and you own every weight of it. GR00T 2 features:
1. Long-horizon tasks: dexterous manipulation and whole-body control chained over 20+ steps and 5+ minutes, such as performing chemistry lab experiments or assembling model airplanes end to end.
2. X-Adapt: adapting from easy data sources (human wearables and simulation) and deploying zero-shot to diverse real robots.
3. Unified Cognition: native integrations with frontier agents for advanced physical reasoning, robust error recovery, and safety monitoring.
It's an open-source buffet! We are releasing not only the model weights and X-Adapt recipes (coming December), but also our agentic framework, simulation engine, annotation engine, hardware design, and even training data (100K hours, that's ~11 yrs of experience), all available today!
Everything that moves will be autonomous. Anyone can become a roboticist.
Lock in, build with us!
Deep dive in thread:
Got Hands? Ep. 02: Aero Hand is stronger than you. Probably (?)
A 5 kg dumbbell. Suddenly, everyone on the team has time for the gym. Come on. We were prepared for AI to outsmart us, but not outlift.
At #CoRL2026? Come meet your new gym rival.
#AeroInAction
“What can your hand actually do?”
We get this a lot, so we filmed a few answers. Introducing Got Hands? One demo at a time.
Ep. 01: The Business Card. You can have it… if I let go. Firm vs. gentle pinch with Aero UMI + Aero Hand.
Find the Chestnut T-shirts at #CoRL2026. Come see if we’ll let you keep the card.
#AeroInAction
Your robot hand feels so close to doing what you need yet there’s still a thin barrier in the way. Let’s cut through it together.
Find us at #CoRL2026. Try Aero UMI + Aero Hand, and explore what co-design could unlock for your research. Spot the Chestnut T-shirt? Come say hi.
Just got back from @HAND_ERC, and the team is on a roll!
We’ll be at @corl_conf this week. Spot someone in this T-shirt? That’s us. Come say hi to try Aero UMI, check out Aero Hand, talk collaboration, or debate whether a rigid, co-designed skeleton is really necessary. Let’s see who wins 😉
We’ll also be at the UMI Arena Device Exhibition on Thursday. Come find us there!

Hot takes from @siyan_hammer at @HAND_ERC. Thanks for having us! We learn from academia and want to give back by building tools researchers can use.
If your lab needs high-fidelity, contact-rich data and a hand designed with deployment in mind from day one, let's talk.

Back from @HAND_ERC! Some hot takes from presentations and conversations with researchers.
1/ Dexterity, robotic hands, and human interfaces are deeply connected.
We can't wait for one problem to be solved before tackling the others. The whole system needs to be designed and improved together from day one.
4
347
Please stop asking us whether hands are for research or deployment. Research and deployment are inseparable.

Higher DoF doesn't necessarily mean better manipulation. Before showing off how many degrees of freedom your robot hand has, show us it can perform reliably, again and again.
Reliability first.

7/ Every extra moving part is a liability
A 21-DoF hand worked in the lab and broke on day one on site. @ChestnutRobotic limits degrees of freedom on purpose. Sensors break first

1
4
286