

Visualize and manage multimodal data in one purpose-built robotics development platform.
Joined February 2021
- Tweets1.8K
- Following468
- Followers5.1K
- Likes1K


Pinned Tweet
Physical AI Industry Night is back! We're again inviting the SF robotics community to join us for drinks, a panel discussion, and networking on November 17th.
Our last Industry Night in May brought together 300 robotics developers and had a waitlist of 1,200+ registrants.
This event will fill up fast, so RSVP soon. All details on the Luma page -> hubs.li/Q04C2Zxs0

Calling France!
We are excited to co-host a Women in Robotics meetup in Paris on November 19. We have a great lineup of speakers:
- Céline Etcheverry, R&D Software Development Director at Balyo
- Lise Delobel, Project Coordinator at Enchanted Tools
- Marine Petriaux, Head of Manipulation at Wandercraft
Doors open at 19:00. Talks start at 19:40, with drinks and networking after.
See you in Paris! Request your spot here: hubs.li/Q04BVKD30

More robots and more logged hours do not make a better robot. A learning loop does.
Raphael Levy, our Head of GTM for Europe, makes this case in IZON. A team running 500 robots without reviewing failures is no further ahead than a team running 50 robots with a tight review loop.
The loop he sees in the teams pulling ahead:
- Understand what happened. Search your full fleet history for every instance of a subtle failure, beyond the one someone flagged by hand.
- Choose the gaps worth fixing. Prioritize failures which recur, carry real risk, or block a customer.
- Fix them with a clean, labeled, retrievable set of examples.
- Confirm the fix against the conditions behind the original failure before you ship to the fleet.
In his example, a warehouse robot misjudges a pallet edge now and then. One clip looks like a one-off. Three months of fleet history trace the misses to one shrink film under one light.
He also cites a 2026 study where 16 dual-arm robots shared one policy and reached a 95% average success rate as fleet experience grew.
A test for your team: name one failure you found, fixed, and confirmed did not come back.
Full article: hubs.li/Q04BwKh50

One of Foxglove's strengths is our community. Case in point: hubs.li/Q04BwM6Q0 's GeoFence Analyzer.
The extension lets you draw a polygon and get the start and end times of the robot trajectory within it. Click on it, and you are teleported to the timestamp of interest.
Want to be part of the community? Check out our Discord: hubs.li/Q04BwM7p0.
Repository: github.com/hippopond/foxglov…

Foxglove retweeted

Nebius open-sourced a Physical AI Workbench this week, built on NVIDIA's stack. And @Foxglove is in there, for observability.
That line made me grin! Doesn’t matter whose cloud or whose GPUs sit underneath, when engineers need to see what their robot actually did, they reach for us.
It’s also a good signal for Europe. Look at who’s already building on it: Moon Surgical, Bellboy Robotics, Sereact. These aren’t hype names, they’re teams shipping fleets and surgical robots into the real world, solving unglamorous problems nobody talks about.
I learned this in martial arts before I learned it in robotics: you don’t improve by doing more reps, you improve by reviewing the tape and fixing the one thing you got wrong. That’s the layer @Foxglove owns. Good to see the industry finally building around that instead of treating it as an afterthought.
nebius.com/blog/posts/physic…

ICYMI: Do robots need to predict the world, or just the next action?
At #Actuate26, leaders from @agilityrobotics, @WaldenRobotics, @shieldaitech, @nvidia, and @bonsairobotics debated VLAs vs. world action models.
Watch the full panel: youtube.com/watch?v=bomg316p…
ICYMI: @physical_int’s robot folded a shirt with zero folding data from that robot. The skill transferred from data on a different robot.
At #Actuate26, Co-Founder @chelseabfinn explained why diverse data is what makes that possible.
Watch the full talk: youtube.com/watch?v=h2E5jDR5…
ICYMI: A robot folding a T-shirt can be 10mm off and still succeed. In manufacturing, 1mm off means the connection fails.
At #Actuate26, @GummadiMeghna shared how Foundry Robotics is teaching foundation models the laws of manufacturing.
Watch the full talk: youtube.com/watch?v=MJcjok0P…
“We didn’t teach it that was a bag.”
At #Actuate26, @GoogleDeepMind VP of Robotics @parada_car88104 showed how Gemini Robotics brings common sense physical reasoning to robots, and why it matters once they take on thousands of tasks.
Watch the full talk: youtube.com/watch?v=erBI_08U…
When an LLM hallucinates, you get a wrong fact. When a self-driving car hallucinates, it might see a green light that’s red.
At #Actuate26, @SebastianThrun explained why robotics has to clear a far higher bar for reliability.
Watch the full keynote: youtube.com/watch?v=U7qYxmSq…
Demo effect is less scary these days.
During our live demo the other day, Lev noticed an issue with his script. Our in-app agent was able to fix the code in < 30 seconds.
If you like AUVs and optimizing robotic cloud workflows, you should check out the recording of the session: hubs.ly/Q04Bqtt30
#robotics
Your robot passed the eval. Now what?
At #Actuate26, @Saronic VP of Software Goutham Subramanian explored one of the hardest problems in robotics: turning strong model performance into real-world reliability.
Watch the full talk: youtube.com/watch?v=Q9iuygYV…
We are live! If you would like some ideas on how to build a robust data platform. Small spoiler: we will feature a small autonomous underwater vehicle (AUV) in Sienne as an example.
Join us here: hubs.li/Q04B9l3K0

See what else we've cooked for 3.4.0: docs.foxglove.dev/changelog/…

Foxglove retweeted
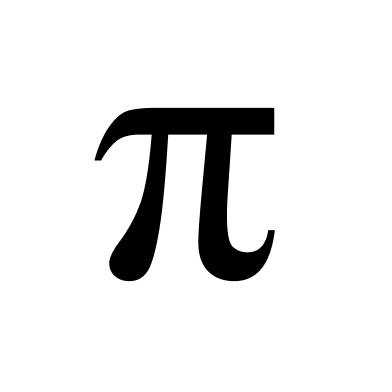
Announcing the beta release of the Pi API. We’ve partnered with companies across diverse industries to adapt our models to their robots and applications, from harvesting strawberries to assembling servers. Now we’re opening access to more teams.
ICYMI: In autonomous construction, the robot is constantly changing the world it has to understand.
At #Actuate26, @BedrockRobotics CTO @kevinmpeterson1 shared how Bedrock turns raw sensor data from dynamic job sites into decisions autonomous heavy equipment can act on.
Full talk: youtube.com/watch?v=2RdLod38…
It's tomorrow!
If you want to automate a big chunk of your robotics workflows, we have solutions.
Join our live stream here: hubs.li/Q04z-M_N0
#robotics #devops

Physical AI is getting a stage of its own at @TechCrunch Disrupt, with leaders building robotics at scale.
Our CEO @adrianmacneil joins @BedrockRobotics CTO @kevinmpeterson1 for “From Prototype to Production: Can It Scale in Reality," in a fireside chat w/ TechCrunch's @kirstenkorosec.
Oct. 14 | 1 p.m. PT
Great company on the Real World AI Stage: @agilityrobotics , @fieldai_, @GM, @hellorobotinc , @medra_ai, @nvidia , @shieldaitech, @SkildAI and @Waabi_ai.
techcrunch.com/events/techcr…
#TechCrunchDisrupt2026
