

Building and Founding Vertex Robotics I train my robots on 100% synthetic data Robotics | Calisthenics | Piano | Tech | Investing Follow for more!
Joined September 2019
- Tweets550
- Following217
- Followers523
- Likes1.2K




Not kidding; yesterday I told a friend about being invited through X for a networking event.
Her: "What's X?"
Me: "former twitter"
Her: "Oh has it changed names?"
WTF?!
Should I do a 100% agentic 1 or 2 day small robot arm build based on the Unitree J288 digital servo's this week?
I'm waiting on PCBs for small bot and carbon for large bot, so have some time to fill and can drive J288 straight from PC
Are there any robots that use an inversed Disney HoloTile for locomotion?
It's definitely a bad idea practically speaking, but that doesn't mean it wouldn't be fun...
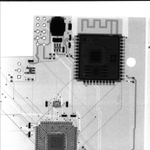
JLCPCB sent me X-ray report of my custom PCB
This is only ESP part + part of connection to STM at bottom of pic
HYPE, it's at shipping center right now

Soooo I have added automated agentic CAD reviews between any two agents (1 MCP + 1 API)
And agents can create RL strategies, run them on cloud GPU through @modal, then reflect on them and improve
Also working on adding automated finite element analysis with feedback loop
If anyone wants to try, send me DM

Yesterday @bubbleboi reposted my turbine comment, so naturally I expected to wake up to all his 110.4K followers following me too.
On a more serious note; how do reposts work, because they don’t show up on the reposters feed?
First 5 DoF leg assembled (hip pitch not in image)
I (clanker) made some small tweaks in design for better printing and cable management
100% designed by clanker™️

Tip for anyone in business:
PLEASE somewhere in your automated mails add the general term of what you do!
I sold an apartment last year but idk the name of the notary and searching for "notary + {address}" gives no results which SUCKS
Again 2026 is crazy.
This morning my clanker designed 10 DoF lower side of humanoid, now have parts semi assembled with perfect fits


Ok should I build this instead?
5 DoF legs with pitch then abduction instead of other way round, this gives way more abduction range.
Complete redesign done by Clanker™️

So... I'm already considernig throwing away this new design. Abduction first makes its range very limited
Should I swap it so I do hip pitch first, then abduction and then add another pair of motors for hip yaw?!
That would make the most versatile setup and I'm waiting for PCB anyway...
Hear me out;
LLMs are almost at the point where they don't need to become smarter for 99% of people (e.g. robotic dev)
Then it will be all about speed and I'm building a fully automated feedback loop app for robotics development
When LLMs start doing 1000+ tok/s, tool calls will become an INSANE bottleneck in comparison
So everything around the LLM needs to be FAST. No excuses