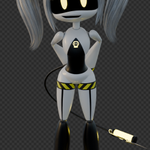
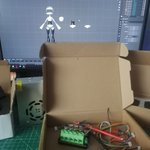
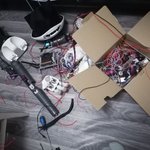
It's been quiet here. Almost finished foot of J. About 50 parts just for one. I'll be back soon and hopefully post more. Hard to model with only motor drawings I still need to order. At least the new leg motors aren't too expensive yet.
HELP
I decided to move away from the strict canon and make something in between the two drone versions. Feels worth it. Thanks to this change I can shove almost all the peripheral electronics into the limbs and free up a ton of space for batteries
While waiting for the programmer and magnetic encoders for the first tests of the updated servos, I started trying on the new motors with J's torso. And yeah, I came to the conclusion that a flat pelvis isn't the most convenient design for this
Even though I found a few interesting options, I really liked an idea from @AlexStariy0303. It's the Disassembler body but with feet. Since the Disassembler torso is much more voluminous, it should hide the actuators better and give more space for electronics
Well, first batch of parts for J finally arrived. Got some stronger actuators, a 24V power supply for testing (though later I'll probably switch to car batteries or even a truck one from a Kamaz).Also received a new motor and driver to test a completely different type
but my 3D printer decided to burn its extruder motor. Nice. On the background there's the second project going. I'm testing my skills on small stuff. V is gonna be around 50 cm tall. It's actually pretty hard because of her body proportions.
Hey guys, I haven't posted anything about J for a long time, so I decided to write this.Right now I'm doing a full rebuild of the entire robot. I completely disassembled the old version because the foundation turned out to be pretty messed up
Also would be nice to finally fix the brakes, because using the handbrake to stop isn't very convenient. Need to redo the gearbox, replace the burnt-out part of the exhaust, and increase the steering angle.