Aerial Robotics, Robots, Manipulation, Research, Professor @TUM

Munich, Germany
Joined June 2018
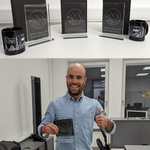
It’s a great pleasure and proud moment to congratulate @TimSalzmann on the successful defense of his PhD thesis at @TUMunich! We’re celebrating not just this milestone, but years of dedication, hard work—and a truly great time together. #PhDDefense #Robotics
1
3
211
My sincere thanks to Marco Pavone, Johannes Betz and Martin Werner for reviewing Tim’s thesis and their valuable participation in the defense. @drmapavone @joebeatzhoven @trajcomp
1
134
Working with Tim has been a real pleasure, both professionally and personally. This is a milestone well earned—and I’m honored to have been part of his journey. 🎓🤖 #PhDGraduation #TUM #RoboticsResearch
109
🤖 PhD Opportunity in Aerial Manipulation! 🚁 Our team is seeking a passionate PhD student to join us in the field of aerial robotics. Requierments: Control, Programming - Application Deadline: 12.10.2024 - Start Date: 01.01.2025 asg.ed.tum.de/aas/stellenaus…
3
363
Feeling humbled and excited that I've received the prestigious Heinz Maier-Leibnitz Award from #DFG! 🥳 This is not just a testimony to my research but to the continuous support of my family, friends, colleagues, and mentors. A heartfelt thank you to each and every one of you!
Replying to @dfg_public
Dr. Katharina Dobs @KathaDobs forscht in der Kognitiven #Psychologie und in den #Neurowissenschaften @jlugiessen. Gratulation zum Heinz Maier-Leibnitz-Preis 2024 der #DFG!
12
5
1
74
11,883
Unlock the power of data-driven models in numerical optimization and optimal control with L4CasADi! :rocket: Check out our latest example showcasing how L4CasADi can optimize a collision-free trajectory through a learned Neural Radiance Field (NeRF). #OptimalControl #L4CasADi
1
9
1
52
11,778
L4CasADi seamlessly integrates optimal control with computer vision models, empowering you to tackle complex problems with ease. [Link to Colab Example][colab.research.google.com/gi…] [Link to paper][arxiv.org/pdf/2312.05873.pdf] Credits go to: @TimSalzmann @jonarriza96 @drmapavone
1
1
12
898
Attending @IEEECDC2023 in Singapore? Come to our talks! ◾ Learning for CasADi ➡github.com/Tim-Salzmann/l4ca… ◾ Pose-Following with Dual Quaternions ➡ arxiv.org/pdf/2308.09507.pdf #CDC23 @MarkusRyll @TimSalzmann
4
18
899
My PhD students @jonarriza96 and @TimSalzmann are presenting their work on Motion Planning and Neural Control at #IROS2023, tomorrow: - youtube.com/watch?v=pOV3pGGc… - github.com/Tim-Salzmann/l4ca… See you at the posters! #Robotic #MIRMI #TUMunich
3
26
2,574
My group @CS_TUDarmstadt has several open #PhD positions on a variety of topics encompassing Interactive #Robot Perception and Learning for Mobile Manipulation Systems -- positions funded by @dfg_public and @HorizonEU Apply now and join us! irosalab.com/open-positions/
28
3
125
19,867
Im Department Aerospace and Geodesy der @ed_tum informieren sich die Abgeordneten über Forschung im "Space Valley": 🚀Raumfahrtantriebe & Mobilität 🤝Arbeitsgemeinschaft @WARR_TUM 🌳Resilienz des Amazonas 🫧Wasserstoffantrieb ⚙️Hochagile Fahrzeuge 🌕Lunar Volatiles Scout
1
5
7
1,241
Markus Ryll retweeted
We are excited to announce the Tartan Planning Series (theairlab.org/tartanplanning…), an interactive series of talks and learning on planning for robotics! Sign up (forms.gle/uwYAgrjMcZnqw2Hs6) to receive reminders and Zoom links to participate.
2
17
6
64
18,006
With Real-time Neural MPC you can efficiently integrate large, complex neural network architectures as dynamics models in an MPC-pipeline. Compared to prior implementations we can leverage neural networks with a 4000x larger parametric capacity in a 50Hz real-time framework.
4
29
1
256
40,305
I feel very honored that my chair has been awarded with three teaching #Awards by the Student Council for Aerospace and Geodesy of #TUM. Congratulations to @jonarriza96. It is a pleasure working with great students and collegues.
2
12
2,235