

Trust layer for Physical AI. Discord: https://xitter.cf/t.co/ZSHFqgb6G9 Telegram: https://xitter.cf/t.co/zhL2ZtQmIr
World
Joined July 2026
- Tweets1.8K
- Following8
- Followers4.9K
- Likes1K




What happens when a robot changes owners?
The transfer involves more than changing the name on a purchase agreement.
1⃣ Machine identity
The robot must remain uniquely identifiable, so the new owner can verify that it is the same machine throughout its lifecycle.
2⃣ Credentials
Certificates, authentication keys, and other access credentials may need to be transferred, reissued, or revoked to prevent the previous owner from retaining unauthorized access.
3⃣ Permissions
Access rules must be reviewed and updated to reflect the new owner’s authority, including which facilities, systems, tasks, and resources the robot can access.
4⃣ Operational history
Maintenance records, software changes, incidents, and relevant activity logs should remain verifiable. Preserving this history helps the new owner understand the machine’s condition and track important changes over time.
5⃣ Ownership records
The change of ownership should be recorded and linked to the machine’s existing identity, creating a verifiable transition between the previous and new owners.
A secure transfer preserves the robot’s identity and history while updating the credentials and permissions that depend on ownership.

As autonomous machines interact with warehouses, infrastructure, and other connected systems, each machine needs clear permissions that define where it can go, what it can access, and which actions it can perform.
Access control follows a verification process ⤵️

2⃣ Check permissions
Evaluate the requested action against the machine’s assigned permissions, access policies, and operational boundaries.
How does a robot prove it’s running the right software?
Remote attestation works in three steps:
1⃣ Generate evidence: The robot measures its boot process and software components, producing cryptographic evidence of its current state.
2⃣ Verify the evidence: A verifier checks the evidence’s authenticity and freshness, then compares the measurements against an approved software reference.
3⃣ Determine trust status:
🔹If the evidence matches the expected state and satisfies the verification policy, the system marks it as verified.
🔹If not, it flags a mismatch for further investigation or action.
This gives other systems a way to independently verify a robot’s software integrity without relying solely on the robot’s own claims.
Attestation confirms a measured software state. It does not guarantee that the software is free of vulnerabilities.

Physical AI this week was about the stack that makes robots useful at scale: better simulation, production humanoids, and data that actually looks like real work.
Here's what made the headlines this week:
1️⃣ @NVIDIARobotics released Isaac Lab 3.0, modular architecture with multi-physics/rendering, Newton integration, RL post-training, and streamlined real-hardware deployment.
2️⃣ @agilityrobotics said Digit 5 will standardize on NVIDIA IGX Thor for onboard compute as it prepares for broader commercial deployment.
3️⃣ @NEURARobotics unveiled 4NE1 Gen 4 (lighter, series-production focused) and opened the TUM RoboGym in Munich for real-world task training.
4️⃣ @UnitreeRobotics introduced the H2-X Kung Fu Legend Guardian, a humanoid pitched for protection and rescue, with ~8 hours of endurance.
5️⃣ @CoreWeave launched Physical AI Launchables, one-command templates for robotics and simulation tools (Isaac Sim, CARLA, MuJoCo).
6️⃣ @Robotiq_Inc launched the 2FC Physical AI Gripper, capturing synchronized touch, force, and position data for robot models.
7️⃣ @Maxinsights announced a $30M seed led by @PeakXVPartners to scale real-world video data (2M+ hours) plus MaxLoop and MaxGlove for quality and force sensing.
Follow @continuumlabs_ for more weekly updates like this.

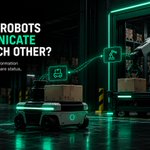
In a warehouse, one robot may deliver a package while another handles the next step. To work together, they need to exchange information about tasks, position, status, and availability.
As autonomous fleets scale, machine-to-machine communication also needs a layer of trust:
▪️Identity: Every machine has a verifiable identity.
▪️Permissions: Each machine operates within its authorized scope.
▪️Verification: Systems can validate the origin and integrity of machine messages.
▪️Operational history: Actions and state changes can be traced over time.
As autonomous fleets grow, reliable communication needs a foundation of verifiable machine identity, permissions, and operational history.
That’s the layer Continuum Labs is building for autonomous machines.

Why does 100 milliseconds matter to a robot?
At 2 m/s, a robot travels an extra 20 cm during a 100 ms delay before its response begins.
In a busy warehouse, that distance can make a difference when a person suddenly crosses its path.
The faster a robot reacts, the better it can respond to changes in its environment.
Reliable autonomy depends on fast feedback loops, predictable response times, and systems that behave as expected.
And for us at Continuum Labs, trust in autonomous machines also means knowing which machine is acting, what it is authorized to do, and having a verifiable record of its actions.

A robot doesn't always need the cloud, as it can process data and make real-time decisions directly on the device, even without an internet connection.
The answer depends on the task. Some decisions need to happen in milliseconds, while others benefit from much larger models and more computing power.
💠 On-device intelligence handles fast reactions, routine tasks, and situations where low latency matters.
💠 Cloud intelligence provides access to larger models, more computing power, and coordination across multiple machines.
Most advanced robotic systems will need a combination of both: local processing for immediate action, and the cloud for tasks that benefit from greater computing resources.

Not every robot needs the cloud to keep working.
Edge computing allows robots to process sensor data, make decisions, and execute certain tasks locally, even when connectivity drops.
But offline autonomy has limits.
Some tasks may need to pause or switch to a safe mode if they depend on remote systems or fresh data.
For autonomous machines, the challenge is maintaining reliable operation while keeping actions accountable.
Continuum Labs focuses on the trust infrastructure behind these systems: verifying machine identity, enforcing permissions, and preserving verifiable operational history, even when a robot temporarily goes offline.
Because losing a connection shouldn’t mean losing control over what a machine is allowed to do.

Robots are getting smarter, but they still struggle with unfamiliar objects, unexpected obstacles, and situations they haven’t learned to handle.
That’s where teleoperation comes in.
A human can take control, guide the robot through a difficult task, and help it recover.
These interventions can also become training data, helping robots learn from human demonstrations and handle similar situations autonomously in the future.
The goal is simple: less human intervention, more reliable autonomy.
But as robots move between autonomous operation and human control, how do we verify who took control, whether they were authorized, and what actions were performed?
Continuum Labs is building trust infrastructure that establishes machine identity, permissions, and a verifiable operational history.

Physical AI this week was about turning models into something you can actually buy and run: an API for robot foundation models, a path to a public humanoid company, and a sub-$2,500 humanoid.
Here's what made the headlines this week:
1️⃣ @physical_int opened the Pi API beta, upload robot data, fine-tune their models on managed compute, and run cloud-hosted inference. Early uses range from strawberry harvesting to server assembly.
2️⃣ @agilityrobotics said the SEC declared its Form S-4 effective for the Churchill Capital Corp XI SPAC deal.
3️⃣ @FaradayFuture unveiled FF Nova, an entry-level EAI humanoid priced under $2,500, and signed a ~$200M all-stock deal to take the robotics business public.
4️⃣ @amazon launched a Physical AI Toolchain on AWS (with NVIDIA) for synthetic data, simulation, edge deployment, and fleet management.
5️⃣ @helm_ai said it has signed $70M in commercial contracts over 12 months and is on a path to operating breakeven.
6️⃣ @BostonDynamics posted a look inside the Atlas shop floor, in-house machining, assembly, and repair aimed at building humanoids at scale.
7️⃣@econsystems introduced NetraVis, a 1MP active-stereo 3D depth camera for robotic perception and obstacle detection.
Follow @continuumlabs_ for more weekly updates like this.

Physical AI faces a data problem: robots need to learn from physical interactions, but collecting those experiences takes time, specialized hardware and human operators.
In 2023, @Google DeepMind’s Open X-Embodiment brought together 1M+ real-robot episodes across 22 robot types, showing the value of pooling diverse robotics data.
The challenge persists in 2026.
@nvidia’s Physical AI Data Factory Blueprint, announced in March, aims to automate data curation, synthetic data generation, and evaluation to reduce the cost and complexity of training at scale.
Meanwhile, companies like DexForce are using simulation to generate training experiences that would be expensive or inefficient to collect entirely in the real world.
Simulation can multiply the data available, but transferring those lessons to physical robots remains difficult.
Models still need diverse real-world experience to handle friction, unexpected objects and changing environments.

What if a robot could practice thousands of times without ever touching a real object?
That’s the idea behind synthetic data for robotics.
Instead of collecting every training example in the physical world, developers use simulations to generate virtual experiences.
A robot can practice picking up objects, adjusting its grip, navigating obstacles, or recovering from mistakes across thousands of different scenarios.
But there’s a catch: simulated physics doesn’t perfectly match the real world. Friction, sensor noise and unexpected physical interactions can cause a robot to fail at tasks it handled successfully in simulation.
That’s why synthetic data works best alongside real-world data and validation. The goal is to help robots learn more efficiently without losing the ability to perform outside the simulation.
As physical AI moves from training environments into real operations, reliable deployment also requires knowing which machine is acting, verifying its integrity and maintaining trustworthy evidence of its state.

A robot drops an object. It tries again, but this time adjusts its grip.
That small correction involves more than repeating an action. The robot needs to detect the failure, interpret sensor feedback, and modify its behavior based on the outcome.
🔹Feedback loops help it identify what went wrong.
🔹Policy adaptation changes how it approaches the next attempt.
🔹 Continual learning can carry those improvements into future tasks through updated training or policies.
The challenge is making sure each adjustment actually improves performance, because a robot that succeeds once may still fail under different conditions.
For autonomous machines, learning from mistakes only becomes valuable when better performance can be demonstrated consistently in the real world.

A robot reaches for a mug but the mug slips. What happens next is a test of its autonomy.
The robot needs to recognize that the grasp failed, use sensor feedback to understand what went wrong, and adjust its next action instead of repeating the same mistake.
Three capabilities make this possible:
🔹 Failure detection identifies the gap between the expected and actual outcome.
🔹 Recovery changes the grip, motion, or strategy in response.
🔹 Verification checks whether the retry actually worked.
Real-world environments rarely behave exactly as expected.
A capable robot must do more than execute a plan; it needs to recognize when that plan has failed and find a way forward.

A robot has learned to recognize a box. But what happens when it encounters an unfamiliar object in an unexpected environment?
This is where its ability to generalize gets tested.
1️⃣ Generalization: Apply learned patterns to new objects and situations instead of relying on exact matches from training.
2️⃣ Out-of-distribution detection: Recognize when an input differs significantly from the data the model has learned from.
3️⃣ Safe adaptation: Respond to uncertainty by gathering more information, reassessing the situation, or choosing a conservative action.
These capabilities work together when a robot encounters something outside its experience. It needs to make use of what it already knows while recognizing when that knowledge may not be enough.
The real test of autonomy is what happens when the environment stops matching the training data.

Physical AI this week was about getting robots onto the floor, not just into a video: a new Boston Dynamics CEO, $110M+ into deployment and training data, and a world model that wants to drive the machine.
Here is what made the headlines this week:
1️⃣ @BostonDynamics named @RohitPrasadAI CEO, former Amazon Alexa / foundation-model lead, to push AI into real-world robot products.
2️⃣ @Ultraroboticsco announced $62M in funding, including a $50M Series A led by @hiFramework, aimed at warehouse deployment rather than demos.
3️⃣ @MeckaAI raised a $60M Series B led by @sequoia (over $120M total) to scale human-motion data and robot deployment.
4️⃣ @axisrobotics partnered with @lotuscars and @GeelyAutoGlobal to put a sim-trained sorting policy on a production line, one policy for 500–800 auto parts.
5️⃣ @odysseyml launched Odyssey-3, a world model it says can be adapted to control robots, humanoids, cars, and drones.
6️⃣ @agilityrobotics held Analyst & Investor Day on Digit 5 and the business, with the replay now up.
7️⃣ @NVIDIARobotics kicked off its Video to Data Challenge, turning human video into robot skills, with three tracks.
Follow @continuumlabs_ for more weekly updates like this.

A car in front of you isn't just a position on the road. It's a moving object with a changing speed, direction, and trajectory.
Autonomous driving systems need to track those changes over time to anticipate what surrounding vehicles might do next.
🔹 Object detection identifies nearby vehicles using cameras and LiDAR.
🔹Object tracking connects detections over time to estimate movement.
🔹Trajectory prediction projects where each vehicle may be in the next few moments.
🔹Continuous updates refine those predictions as new sensor data arrives.
As new sensor data arrives, the system updates its estimates and responds to changes in traffic.
The goal is to give the vehicle time to anticipate what’s happening around it, rather than react only after a situation develops.
