

Urbana, IL
Joined April 2017
- Tweets38
- Following159
- Followers223
- Likes121





📢 Call for Papers — ICRA26 Workshop:
Bridging the Gap between Robot Learning and Human-Robot Interaction
📅 June 5, 2026 | Vienna, Austria
📝 Submit: openreview.net/group?id=IEEE…
👉 Website: sites.google.com/vt.edu/icra…
#ICRA2026 #robotics #HRI
@dplosey @xuehui_yu @haroldsoh @yukez

📌 Topics:
• Robot learning methods for humans to teach robots
• HRI studies that evaluate user expectations and inform robot learning design
• Aligning assumptions between human users and robot learners
• Frameworks integrating technical learning with human factors
Despite remarkable advances in robot learning and HRI, there is a gap between the two fields and many researchers in the two fields make simplified assumptions about each other. This workshop is a space to change that.
📢 Call for Papers — ICRA 2026 Workshop:
Bridging the Gap between Robot Learning and Human-Robot Interaction
📅 Date and location: June 5th, 2026 | Vienna, Austria
📝 Submit: openreview.net/group?id=IEEE…
👉 Website: sites.google.com/vt.edu/icra…
#ICRA2026 #robotics #HumanRobotInteraction
I've been postponing the announcement of this news due to my job search, but here we go:
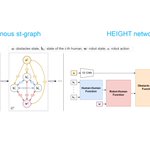
Super excited to share that HEIGHT is accepted by IEEE Transactions on Automation Science and Engineering (T-ASE)! And please enjoy our deployment videos on Speedway and GDC Atrium😆

Shuijing Liu retweeted

After 6 years as director of Texas Robotics, I'm delighted to hand over the reigns to the capable hands of Prof. Jose Millan. I'm honored to continue supporting Jose in my new role of "Founding Director" as I turn my main focus to acting as Chair of the UT Computer Science Dept
Shuijing Liu retweeted

What if robots could decide when to see and when to feel like humans?
We built a system that lets them.
Multi-Modal Policy Consensus learns to balance vision 👁️ and touch ✋.
🌐 Project: policyconsensus.github.io 1/N
How to scale instruction following policies from simple to complex instructions without re-training? Checkout our ComposableNav paper below (also presented in CoRL 2025)!

How can robots follow complex instructions in dynamic environments?
🤖 Meet ComposableNav — a diffusion-based planner that enables robots to generate novel navigation behaviors that satisfy diverse instruction specifications on the fly — no retraining needed.
📄 Just accepted to CoRL 2025
🔗 Project: amrl.cs.utexas.edu/Composabl…
A Thread (1/8)
After you bought new grocery items that your robot has never seen before, how can the robot quickly learn to sort these items on the fly? Please check out our MimicDroid paper below!

Intelligent humanoids should have the ability to quickly adapt to new tasks by observing humans
Why is such adaptability important?
🌍 Real-world diversity is hard to fully capture in advance
🧠 Adaptability is central to natural intelligence
We present MimicDroid 👇
🌐 ut-austin-rpl.github.io/Mimi…
Are VLMs good at scene understanding for social navigation? Turns out SOTA VLMs are worse than humans and rule-based methods in some cases.🤔For details, please check our SocialNav-SUB (accepted in CoRL 2025)!

[1/8] New social navigation paper + benchmark: SocialNav-SUB 🚶🤖 Recent work puts VLMs on robots for navigation, but can they really interpret scenes and extract key details for social navigation? 🔎 larg.github.io/socialnav-sub


What a fun and rewarding experience at #RSSPioneers2025! Special thanks to the organizers and sponsors!

Hope you have an enjoyable start of the @RoboticsSciSys 2025!
On behalf of the organizing committee, we'd like to thank everyone for their contributions to the #RSSPioneers2025 workshop! We hope that it was an unforgettable and inspiring experience for our Pioneers!

If you’re attending RSS in LA, feel free to check out my RSS Pioneers lightening talk (~11:30-11:35am) and/or poster session!
I'll share my past work and future vision on robot learning for and from human interactions.
@RSSPioneers @RoboticsSciSys @ECEILLINOIS @texas_robotics
📢 Checkout our recent work Casper👻, a VLM-powered assistive robot!
This work is also a meaningful milestone as my first postdoc project.
This upcoming week, I'll be at ICRA (Mon-Fri) to present 1 RA-L paper, 1 ICRA paper, and 4 workshop papers. Looking forward to connect to old and new colleagues in Atlanta!


Excited and honored to share that I’m selected as an RSS pioneer! Huge thanks to my colleagues and the organizers who made this possible! If you’re also attending RSS in LA, I’d be happy to connect.
List of 33 #RSSPioneer2025 is out! Their research interests cover fundamental robot design, modelling and control, robot perception and learning, localisation and mapping, human-robot interaction, healthcare and medical robotics, and soft robots!
sites.google.com/view/rsspio…

Very interesting topic, organized by multiple colleagues of mine. Please check it out!

Excited to organize Workshop on Learning Meets Model-Based Methods for Contact-Rich Manipulation @ ICRA 2025!
We welcome submissions on a range of topics—check out our website for details:
contact-rich.github.io/
Join us for an incredible lineup of speakers! #ICRA2025

Please checkout our ICLR 2025 workshop on human-AI co-evolution!

Excited to announce the ICLR 2025 Workshop on Human-AI Coevolution with @aiprof_mykel, @Diyi_Yang, @sanmikoyejo, David Hsu & more!
#AI #HumanAIInteraction #ICLR2025 #AIResearch #EthicalAI #HCI
