

humanoid robots | Automation | AGI | ASI | Tracking the rise of autonomous systems and the future of intelligence Physical AI embodied
Etats-Unis
Joined October 2021
- Tweets8.7K
- Following995
- Followers18.9K
- Likes23.5K




Hiring engineers for robotics and hardtech is difficult to get right from a résumé alone.
Colare takes a different approach: candidates solve real engineering problems in tools like CAD and PCB design, and their process is evaluated alongside the final result.
I like this approach because engineering is about trade-offs, technical judgment, and how you solve problems under real constraints.
Colare just announced a $2.5M pre seed round to build this for hardtech hiring.
Congrats to @esthxrtho and Nain Abdi on the launch.
Book a demo at colare .com
🤝 Paid partnership

We’ve raised a $2.5M pre-seed to fix hardware hiring.
The most reliable way to know if an engineer can do the job is to watch them work.
In hardware, that’s been almost impossible to do at scale.
Colare runs simulation-based assessments that show how candidates actually work, in the tools they’d use on the job, before anyone books an interview.
We assess across:
- Mechanical (CAD, DFM, FEA)
- Electrical (PCB, schematics)
- Systems
- Manufacturing, & more.
Candidates solve problems from first principles.
Hiring teams see that across their whole pool, so engineers only interview people who’ve already cleared the bar.
We're already working with everyone from seed-stage startups to multi-billion-dollar aerospace manufacturers.
If you’re hiring hardware engineers, let’s talk:
colare.com/
RoboParty built a humanoid robot in 4 months. Now, the full project is open source.
ROBOTO ORIGIN stands about 1.25 m tall, weighs 34 kg and has 23 degrees of freedom.
The technical details:
• 120 Nm peak torque at the leg joints
• 48 V, 15 Ah battery
• Mechanical CAD, PCB designs and BOM
• Firmware, motor control and ROS 2 deployment
• URDF/MJCF models for simulation
• Reinforcement learning with Isaac Lab and RSL-RL
• Sim-to-sim transfer to MuJoCo and sim-to-real validation
The robot can walk, run and jump.
What caught my attention is the training to hardware workflow.
You can study how learned motion policies move from simulation to a physical humanoid.

NEURA Robotics has unveiled the 4NE1 Gen 4.
The new version is 20% lighter, with a slimmer body, black textile covering and upgraded hands for more precise gripping.
One detail worth watching is its “smart limbs.” Each limb has local reflexes and can respond independently to changes around it.
The robot runs on Neuron AI, combining 3D vision, touch, force, audio and internal body-state data.
It learns from real robot data, human demonstrations and simulation.
Skills can also be shared across connected robots through the Neuraverse platform.
The 4NE1 Gen 4 is already operating in NEURA’s training facilities and is being prepared for series production.
Ever wondered how many different robotics problems one company can tackle?
Pollen Robotics has developed a range of projects covering humanoid robots, locomotion, grasping and robot learning.
Here are 6 projects to know:
1. Reachy 2: A humanoid robot for research, manipulation and human-robot interaction.
2. Reachy Mini: A desktop robot for AI experiments, voice interaction and creative coding.
3. Microduck: A compact bipedal robot exploring walking, sensing and object interaction.
4. AmazingHand: An open-source robotic hand project.
5. PincOpen: An open-source parallel gripper for grasping objects.
6. Grabette: A data collection project connected to robotics learning workflows.
What caught my attention is the variety of hardware involved. Walking, manipulating objects and collecting robot training data each require different engineering approaches.
Pollen Robotics joined Hugging Face in 2025.
Which project would you choose to work on?
Save this, you'll need it.
10 robotics events in November 2026:
🇺🇸 USA
3–4 Humanoid Robots Summit, Chicago
3–5 Robot Safety Conference, Detroit
9–12 Conference on Robot Learning, Austin
🇪🇺 Europe
5–6 Humanoid Europe, Munich
13 Swiss Robotics Day, Zurich
18–20 Iberian Robotics Conference, Barcelona
24–26 SPS, Nuremberg
🇨🇳 China
5–10 CIIE, Shanghai
19–21 World Intelligent Manufacturing Expo, Nanjing
26–28 China Hi-Tech Fair, Shenzhen
…and many more events worldwide
The US humanoid robotics scene spans 22 companies and research teams.
I mapped their headquarters across the country, from Silicon Valley to Texas, Boston and New York.
The list includes:
• Tesla
• Figure AI
• Boston Dynamics
• Apptronik
• Agility Robotics
• 1X Technologies
• Foundation
• Sunday Robotics
• Persona AI
• Fauna Robotics (Amazon)
• Faraday Future
• Dexterity
• Noble Machines
• Rhoda AI
• Genesis AI
• Dexmate
• Robot .com
• Weave Robotics
• Reflex Robotics
• Bear Robotics
• Richtech Robotics
• IHMC
The Bay Area has the largest cluster on this map, with 12 entries. Austin also has a presence, with Tesla and Apptronik based there.
What caught my attention is how many companies are concentrated around Silicon Valley, while other teams are spread across Texas, Massachusetts, New York and Oregon.
Which of these companies do you think will lead the US humanoid robotics race?
Which companies have I left out?

I share many more robotics events on my site :
techniahqrobot.com/evens
The US humanoid robotics scene spans 22 companies and research teams.
I mapped their headquarters across the country, from Silicon Valley to Texas, Boston and New York.
The list includes:
• Tesla
• Figure AI
• Boston Dynamics
• Apptronik
• Agility Robotics
• 1X Technologies
• Foundation
• Sunday Robotics
• Persona AI
• Fauna Robotics (Amazon)
• Faraday Future
• Dexterity
• Noble Machines
• Rhoda AI
• Genesis AI
• Dexmate
• Robot .com
• Weave Robotics
• Reflex Robotics
• Bear Robotics
• Richtech Robotics
• IHMC
The Bay Area has the largest cluster on this map, with 12 entries. Austin also has a presence, with Tesla and Apptronik based there.
What caught my attention is how many companies are concentrated around Silicon Valley, while other teams are spread across Texas, Massachusetts, New York and Oregon.
Which of these companies do you think will lead the US humanoid robotics race?
Which companies have I left out?
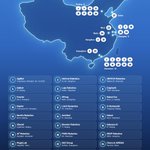
🇨🇳 The 30 Chinese leaders in humanoid robotics:
• 1 AgiBot
· 2 Unitree
· 3 UBTECH
· 4 Galbot
· 5 Leju Robotics
· 6 EngineAI
· 7 Fourier
· 8 XPeng
· 9 Robot Era
· 10 Kepler
· 11 LimX Dynamics
· 12 X-Humanoid
· 13 Noetix Robotics
· 14 Astribot
· 15 Dobot
· 16 Xiaomi
· 17 Booster Robotics
· 18 Galaxea AI
· 19 AI² Robotics
· 20 PUDU Robotics
· 21 DEEP Robotics
· 22 MagicLab
· 23 GAC
· 24 Chery & AiMOGA
· 25 X Square Robot
· 26 Keenon Robotics
· 27 EX-Robots
· 28 Lingbao CASBOT
· 29 Tencent Robotics X
· 30 Shanghai Humanoid Center
The list isn’t finished yet. I’m going to complete it with another graphic and turn it into a thread.
Unpopular opinion: the best home robot might be one that does nothing for you.
Mori, from One Kind Artifact (OKA), won't answer every question, control your smart home or handle household chores. That's part of its design.
It looks like a soft mushroom lamp. Small movements, changes in light and sound, and guided breathing exercises are how it interacts with you.
No long conversations. No list of tasks. Just a quiet presence in the room.
The details:
• Around 30 cm tall
• Camera and microphones
• On-device AI processing, according to OKA
• $649 launch price for the limited Founder Edition
What caught my attention is how little Mori asks from its owner. Most home robots are built around tasks. Mori takes a different approach, focusing on how a robot makes you feel.
Would you spend $649 on a robot for companionship, or would you rather have one that actually does things around the house?
Footage: @onekindartifact
Before you build a robot, watch this.
Here are 18 open source robots,
shown with their 3D models.
1. Microban
2. MiniLoong
3. Poppy Humanoid
4. Otto DIY
5. pib
6. Mini Pupper
7. Petoi Bittle
8. Stanford Doggo
9. SpotMicro
10. OpenQuadruped
11. Puguette
12. SO-ARM100
13. RoArm-M2
14. OpenMANIPULATOR-X
15. LeKiwi
16. TurtleBot3 Burger
17. OpenBot
18. Duckiebot
These projects cover humanoids, quadrupeds, robotic arms and mobile robots.
Before building, check each project's official repository. Hardware specifications, 3D design files and licences vary between projects.
My personal pick would be SO-ARM100. I'd like to explore its design and see what I could build with it.
Which of these 18 robots would you build first?
3D model credits: Microban (Rhoban, CC BY-NC-SA 4.0) · Poppy Humanoid (Poppy Project, CC BY-SA 4.0) · Otto DIY (ottobot. org, CC BY-SA 4.0) · SpotMicro design by Deok-yeon Kim / KDY0523 (CC BY 3.0) · OpenBot wheel model: FreeCAD library (CC BY 3.0) · Duckiebot model: Duckietown (duckietown. com) · All other models from their respective project repositories.
I’m seeing more and more people download videos from X and reupload them to X.
It costs nothing to copy the link and add "/video/1" at the end
X already provides this feature, so why download and reupload when you can share the original video link?
Before you build a robot, watch this.
Here are 18 open source robots,
shown with their 3D models.
1. Microban
2. MiniLoong
3. Poppy Humanoid
4. Otto DIY
5. pib
6. Mini Pupper
7. Petoi Bittle
8. Stanford Doggo
9. SpotMicro
10. OpenQuadruped
11. Puguette
12. SO-ARM100
13. RoArm-M2
14. OpenMANIPULATOR-X
15. LeKiwi
16. TurtleBot3 Burger
17. OpenBot
18. Duckiebot
These projects cover humanoids, quadrupeds, robotic arms and mobile robots.
Before building, check each project's official repository. Hardware specifications, 3D design files and licences vary between projects.
My personal pick would be SO-ARM100. I'd like to explore its design and see what I could build with it.
Which of these 18 robots would you build first?
3D model credits: Microban (Rhoban, CC BY-NC-SA 4.0) · Poppy Humanoid (Poppy Project, CC BY-SA 4.0) · Otto DIY (ottobot. org, CC BY-SA 4.0) · SpotMicro design by Deok-yeon Kim / KDY0523 (CC BY 3.0) · OpenBot wheel model: FreeCAD library (CC BY 3.0) · Duckiebot model: Duckietown (duckietown. com) · All other models from their respective project repositories.
Most people miss this one detail about robot datasets: failure is data too.
AGIBOT WORLD 2026 Release 4 focuses on physical reasoning. The robot must track objects handle occlusion respect space constraints and decide what to do next.
The dataset covers 9 reasoning abilities from goal-directed search to long-horizon planning across everyday tasks like shelf restocking, room cleaning and finding hidden objects.
It includes successful and failed attempts detailed task annotations camera videos robot states and action data collected on the AGIBOT G2.
My observation labeling why a robot failed could be as useful as recording how it succeeded.
Techniahqrobot | humanoid robots retweeted
Most people miss this one detail about robot datasets: failure is data too.
AGIBOT WORLD 2026 Release 4 focuses on physical reasoning. The robot must track objects handle occlusion respect space constraints and decide what to do next.
The dataset covers 9 reasoning abilities from goal-directed search to long-horizon planning across everyday tasks like shelf restocking, room cleaning and finding hidden objects.
It includes successful and failed attempts detailed task annotations camera videos robot states and action data collected on the AGIBOT G2.
My observation labeling why a robot failed could be as useful as recording how it succeeded.
Stop throwing away your old phone. It could still be useful.
Here's why.
Why do robots have to look like humans?
Meet EELS a 4-meter 100 kg snake like robot developed by NASA JPL to explore terrain where wheels and legs struggle.
It uses rotating screw threads to move across snow sand and ice while lidar and stereo cameras help it map its surroundings.
The original goal? Explore the icy moon Enceladus in search of signs of life.
EELS is still a prototype but it raises an interesting question are we designing robots for how humans move or for what the environment demands?
This is next level.
Claude turning a simple prompt into a fully interactive 3D office with live Tavus PALs at every desk a Corvette racing game with a PAL sidekick Griffstation mini games and all those easter eggs is pure magic.
The level of polish and playfulness is insane.

I asked Claude to build an office for the @tavus PALs...
I was not expecting it to build THAT kind of office
Why do robots have to look like humans?
Meet EELS a 4-meter 100 kg snake like robot developed by NASA JPL to explore terrain where wheels and legs struggle.
It uses rotating screw threads to move across snow sand and ice while lidar and stereo cameras help it map its surroundings.
The original goal? Explore the icy moon Enceladus in search of signs of life.
EELS is still a prototype but it raises an interesting question are we designing robots for how humans move or for what the environment demands?
There's one thing 99% of people don't know about openArm 2.0
What if a robot arm could let you feel what it touches?
That is the idea behind bilateral teleoperation on OpenArm 2.0, the open-source humanoid arm developed by Enactic.
How it works:
1. A human moves a leader arm.
2. The follower arm copies the motion, joint by joint.
3. When the follower hits resistance, its motors register the extra load.
4. That force is sent back to the leader, so the operator feels the contact and adjusts.
Why it matters:
Many robot learning methods start with human demonstrations recorded by teleoperation. If the operator cannot feel contact, they push too hard, crush objects or stop too early.
Force feedback gives gentler more precise demonstrations which means better training data for imitation learning.
Key specs:
7 joints per arm: shoulder elbow and wrist
A camera inside each gripper for close-range vision
4.1 kg nominal payload per arm, gripper included
6 kg peak payload for short durations
Full mechanical design available: STEP, STL and URDF files
MuJoCo simulation models included
Reality check:
Open hardware is not plug and play. Autonomous manipulation still needs control software, calibration and a lot of testing.
Would you build one to collect your own training data?