
Recording paper notes by @chongzzzhang who is interested in robot learning
busy with paperwork recently
Joined March 2024
- Tweets519
- Following1
- Followers3.4K
- Likes14




arxiv.org/pdf/2609.08224
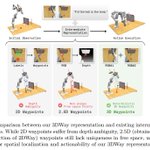
3DWay: Generalizing Robot Manipulation via 3D
Consistent Waypoints
two view wapoints -> triangulation -> better spatial representation for VLM to output after finetuning


TANGO : Humanoid Navigation in Cluttered Environments with a Whole-Body Vision-Language-Action Model
arxiv.org/pdf/2609.09158
VLA motion generation + sonic tracker. Dataset includes whole body motions. A small step towards WBC + VLN.


arxiv.org/pdf/2609.08209
Monkey See, Can Monkey Do? A Benchmark for Evaluating Robot Skill Learning by Observation
A dataset with paired human demo and robot simulation data. Good idea for scene understanding in manipulation.

C's Robotics Paper Notes retweeted

arxiv.org/pdf/2609.08511v1
PGMT is probably the best tracking paper I've seen. It can walk on stairs or a 40cm box while tracking ref, without modifying the flat ground reference.
No reference-terrain adaptation, cheap training. The model arch design is the key and is very smart.

C's Robotics Paper Notes retweeted
New paper release: Learning Agile Perceptive Traversal of Sparse 3D Structures for Humanoids
Paper arxiv.org/pdf/2608.29769
Videos nemantor.github.io/sparse-3d…
We study how to do learning and sim2real for 3d traversal, such as monkey bars and overhanging obstacles.
arxiv.org/pdf/2608.18234v1
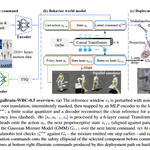
gigabrain wbc 0.5
1. Pair reference with terrain primitives to afford contacts
2. Enabling motion tracking on terrains/object contacts via such data
3. Use next state and latent prediction, plus GMM check to filter out unsafe OOD commands.

back to life. first paper to update here is adept.
adept-dexterity.github.io/
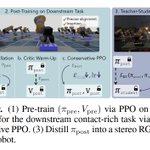
1) pretrain multiple skills
2) BC-RL fnetuning
3) Distill a visual student
Achieves skillful precise manipulation via sim2real

ULTRA: Unified Multimodal Control for Autonomous Humanoid Whole-Body Loco-Manipulation
arxiv.org/pdf/2603.03279
1. RL based retargetting
2. multi-modal command student distillation and finetuning so that it can switch between goal reaching vs reference tracking, mocap vs depth


HoMMI: Learning Whole-Body Mobile Manipulation from Human Demonstrations
arxiv.org/pdf/2603.03243
for cross-embodiement transfer:
1. use look-at points in 3D space instead of direct head states
2. mask out arms

Watch Your Step: Learning Semantically-Guided Locomotion in Cluttered Environment
arxiv.org/pdf/2603.02657
this works shows you can train a policy plus using a semantic map to avoid stepping on valuable things.
this is why I believe locomotion should all be mapping based.

arxiv.org/pdf/2602.21723
LESSMIMIC: Long-Horizon Humanoid Interaction with Unified Distance Field Representations
use distance field (DF) as a representation for HOI. each link's traj can be defined by DF + grad of DF + vel_norm + vel_tangent.
(tbc)

arxiv.org/pdf/2603.01126v1
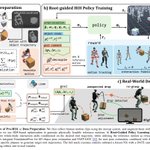
Pro-HOI: Perceptive Root-guided Humanoid-Object Interaction
trained with mimic + contact commands, but deployed with planner to replace the reference.

arxiv.org/pdf/2602.18164
The grandtour dataset, with tons of odometry methods benchmarked in tons of environments.


hero-humanoid.github.io/stat…
Learning Humanoid End-Effector Control for Open-Vocabulary Visual Loco-Manipulation
For humanoid EE goal reaching, on top of WBC pose tracking, a neural model is trained to further correct small biases near the goal.

VIGOR: Visual Goal-In-Context Inference for Unified Humanoid Fall Safety
arxiv.org/pdf/2602.16511
visual humanoid fall recovery
1) flat terrain human sparse reference
2) terrain-aware ref adjustment
3) keypoint tracking teacher
4) distilled to visual student without keypoint obs

arxiv.org/pdf/2602.15733v1
meshmimic: Geometry-Aware Humanoid Motion Learning through 3D Scene Reconstruction
kinda like CRISP + OmniRetarget, but: 1) uses human edge and excludes depth edge in image to extract contacts, which is smart; 2) use polygonal primitives for clean scenes


arxiv.org/abs/2602.11758
Humanoid Agile Object Interaction Control via Dynamics-Aware World Model
predict object states from proprioceptive obs, use it to transform object template pointcloud, and embed the transformed pcl as policy inputs.

apex-humanoid.github.io/
reward engineering + state machine engineering + nice progress-based rewards for reference-free humanoid agile climbing learning.
