
PhD student. Computer Vision/Machine Learning
Joined March 2021
- Tweets60
- Following112
- Followers105
- Likes134






Pinned Tweet
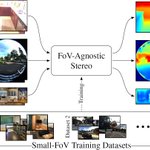
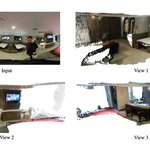
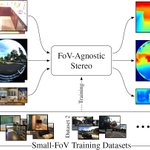
🚀 Excited to release the code from our #3DV2024 oral presentation: FoVA-Depth: Field-of-View Agnostic Depth Estimation for cross-dataset generalization! 📊
🔗 Project details: research.nvidia.com/labs/lpr…
🔗 Code: github.com/NVlabs/fova-depth (1/8)

🎉 Congrats on DAC and the CVPR’25 acceptance!
We explored a similar idea for stereo in FoVA-Depth (3DV’24 oral):
📌 Warp pinhole to canonical ERP to generalize across camera models.
Glad to see this working in monocular too!
📄 Project: research.nvidia.com/labs/lpr…
💻 Code: github.com/NVlabs/fova-depth
🧵 Original tweet: xitter.cf/daniel_lichy/status/18…
#CVPR2025 #DepthEstimation #360Images


🎉 We’re excited to announce our paper Depth Any Camera (DAC), accepted to 𝗖𝗩𝗣𝗥 𝟮𝟬𝟮𝟱! 🚀
Along with this, we have a few exciting updates!
To support NeRF & Gaussian Splatting on fisheye inputs, we now provide DAC’s depth estimation results for #ZipNeRF on fisheye images.
📥 Download depth maps:
🔗 yuliangguo.github.io/depth-a…
Methods like #SMERF, #FisheyeGS, & #EVER can leverage this fisheye depth prior!
#CVPR2025 #NeRF #GaussianSplatting #3DReconstruction #ComputerVision
🔧Also, check out our library nvTorchCam, built for seamless PyTorch workflows across pinhole, fisheye, ERP, and other camera models.
💻 github.com/NVlabs/nvTorchCam
Daniel Lichy retweeted

Light of Normals: Unified Feature Representation for Universal Photometric Stereo
Hong Li, Houyuan Chen, @ychngji6, @Frozen_Burning, Bohan Li, @xshocng1, Xianda Guo, Xuhui Liu, Yikai Wang, Baochang Zhang, Satoshi Ikehata, Boxin Shi, @raoanyi, @HaoZhao_AIRSUN
tl;dr: learnable light register tokens; wavelet transform-based sampling; normal-gradient perception loss
arxiv.org/abs/2506.18882


Daniel Lichy retweeted

🚀 Introducing ProJo4D — a new method for Inverse Physics estimation: recovering 3D shape and physical behavior of deformable objects.
It can simulate future motion and render novel views — all from sparse multi-view videos!
🔗 daniel03c1.github.io/ProJo4D…
Exciting update! 🎉
🔑 By popular demand, nvTorchCam is now under the Apache License 2.0.
🛠️ Get the code: github.com/NVlabs/nvTorchCam
📄 Check out the arXiv article: arxiv.org/abs/2410.12074
🎥 Demo video below:
Big thanks to @zhenjun_zhao for spreading the word! 🙌 #opensource #AI #python #arxiv

🎉 Thrilled to introduce nvTorchCam, our new #PyTorch library designed to support the development of models using camera geometry like plane-sweep volumes (PSV) and related concepts like sphere-sweep volumes or epipolar attention, in a camera model-agnostic way! 🚀
🔗 Code: github.com/NVlabs/nvTorchCam
(1/6)


Daniel Lichy retweeted

Proud of this project led by @daniel_lichy. FoVA-Depth is our answer to a problem we experience in many projects: for uncommon cameras, eg fisheye, we don't have as much training depth data as we do for pinhole cameras.
🚀 Excited to release the code from our #3DV2024 oral presentation: FoVA-Depth: Field-of-View Agnostic Depth Estimation for cross-dataset generalization! 📊
🔗 Project details: research.nvidia.com/labs/lpr…
🔗 Code: github.com/NVlabs/fova-depth (1/8)
Daniel Lichy retweeted

🚀 Ready to take 3D reconstruction to the next level? Whether you're working on NeRF or 3DGS, our new method, GLOMAP, is here to impress! 🌟 It's faster and more accurate than COLMAP on several datasets.
🌐 Website: lpanaf.github.io/eccv24_glom…
@mapo1, @LinfeiPan, J. Schönberger
🛠️ Also, check out our nvTorchCam library at github.com/NVlabs/nvTorchCam. It offers tools for building cost-volumes for various camera models. I hope our FoVA-Depth methods will soon be applied in new technologies, such as generalizable #GaussianSplatting techniques like MVSGaussian mvsgaussian.github.io/ ✨ (7/8)

🙌 A big thank you to my co-authors at NVIDIA: @suhangpro, Abhishek Badki @0razio , and @jankautz! #MachineLearning #ComputerVision (8/8)
Daniel Lichy retweeted
Accepted to #ECCV2024, version 2 of our past 'Accidental Light Stage' work (grail.cs.washington.edu/proj…). We can perform real-time temporally consistent relighting by using monitor relighting in any condition (*as long as the monitor light has some relative strength).

Daniel Lichy retweeted
📢Doing 3D learning on datasets captured with different camera/image models, eg a mix of pinholes and fisheyes or ERPs?
With #nvTorchCam write the code once and forget about it, and you can even batch them all together!
github.com/NVlabs/nvTorchCam
Let us know what you think!
🎉 Thrilled to introduce nvTorchCam, our new #PyTorch library designed to support the development of models using camera geometry like plane-sweep volumes (PSV) and related concepts like sphere-sweep volumes or epipolar attention, in a camera model-agnostic way! 🚀
🔗 Code: github.com/NVlabs/nvTorchCam
(1/6)
What do you think of nvTorchCam? Could it assist in your research or applications? We’d love to hear your feedback and potential uses!
(5/6)
For more insights and applications, also check out our project FoVA-Depth. Stay tuned for more details on FoVA-Depth coming soon! 🚀
🔗 Project_Page: research.nvidia.com/labs/lpr…
🔗 Code: github.com/NVlabs/fova-depth…
(6/6)
🎉 Thrilled to introduce nvTorchCam, our new #PyTorch library designed to support the development of models using camera geometry like plane-sweep volumes (PSV) and related concepts like sphere-sweep volumes or epipolar attention, in a camera model-agnostic way! 🚀
🔗 Code: github.com/NVlabs/nvTorchCam
(1/6)