
PhD Student @CarnegieMellon | BS @Tsinghua_Uni.
Joined July 2023
- Tweets24
- Following279
- Followers138
- Likes45

Pinned Tweet
Check out KPI: a general real-time interaction kernel on top of a humanoid whole-body tracker, unlocking diverse contact-rich loco-manipulation while preserving general-purpose tracking. Pair it with a powerful agent like GPT-6 Astra to turn high-level instructions into physical interaction!

What can GPT-6 Astra do on a humanoid when the contact gets hard?
Give it the right interaction kernel.
Led by @yk20wang, our team presents KPI: A Promptable Kernel for Physical Interaction on Humanoids.
With our agentic system, Astra completes long-horizon, contact-rich tasks zero-shot—no task demos or task-specific training.
1/6
Yikai Wang retweeted

With @JayHe748646 @KehanWen170077 @leggedrobotics , we push humanoid mobility to next frontier.
Achieved by a generalist contact planner + a generalist tracker + a generalized neural mapping, warmstarted from few human data.
Website: leggedrobotics.github.io/ACP…
Promo Video 👇
Yikai Wang retweeted

Humanoids can learn new skills by tracking high-quality reference motions, which today come from humans through motion capture or video. Routing every reference through a human proxy limits scalability and compounds reconstruction errors with the embodiment gap. KinoGen synthesizes loco-manipulation references directly for the target robot through kinematically grounded video generation. 🧵 (1/7)
Yikai Wang retweeted

A robot can follow a reasonable interpretation of an instruction and still fail the benchmark.
Meet BenchMend: we use GPT-6-Astra to uncover instruction–verifier gaps in robotics benchmarks, then repair the wording while preserving success checkers and recorded demonstrations.
Key takeaways:
📝 Instructions matter. Small edits can substantially improve alignment between task language and benchmark verdicts.
🤖 Even strong agents have limits when performing zero-shot robot control. Tasks requiring precise contact, placement, and coordination remain challenging for agents.
🛠️ An imperfect policy can still help debug benchmarks. Agents that diagnose gaps, propose fixes, and test them could enable self-improving benchmarks and potentially support recursive self-improvement (RSI).
Read the blog: tianqi-zh.github.io/BenchMen…
Watch the rollouts: huggingface.co/spaces/benchm…
Yikai Wang retweeted

GPT-6 Astra is already showing up in more and more robot demos.
KPI offers a glimpse of what that could mean.
Astra handles the task, scene understanding and motion planning. KPI then turns those high-level intentions into real-time physical interaction, adjusting stiffness, damping, force and motion as the robot makes contact with the world.
Astra decides what to do.
KPI helps the robot figure out how to physically do it.
Let's discuss this--
As foundation models learn more from robots and real-world experience, how much of today’s specialized Physical AI stack will eventually be absorbed into the foundation model itself?
What's your take on this?
What can GPT-6 Astra do on a humanoid when the contact gets hard?
Give it the right interaction kernel.
Led by @yk20wang, our team presents KPI: A Promptable Kernel for Physical Interaction on Humanoids.
With our agentic system, Astra completes long-horizon, contact-rich tasks zero-shot—no task demos or task-specific training.
1/6
Yikai Wang retweeted

Your fine-tuned VLA does most of a long-horizon task, then gets stuck at a few critical steps.
Don't retrain it. Don't collect more demos of what already works.
Let it practice the part that fails, on the real robot.
PARTS, w/ @ling_feng_sun (project lead) 🧵
1/8
Yikai Wang retweeted

We introduce KIWI: a modular robot-data rig built around Insta360 cameras.
Voice-controlled capture. No carried computer or trackers.
Ego/wrist video, training-ready motion and a 3D scene—from the same recording.
1/5
Yikai Wang retweeted

A short visa delay could force incoming CMU graduate students to defer for a full academic year. If you are affected, join our request for Fall 2026 late arrival or Spring 2027 entry. Anonymous participation is available:
docs.google.com/forms/d/e/1F…
#CMU #InternationalStudents

Yikai Wang retweeted
New paper release: Learning Agile Perceptive Traversal of Sparse 3D Structures for Humanoids
Paper arxiv.org/pdf/2608.29769
Videos nemantor.github.io/sparse-3d…
We study how to do learning and sim2real for 3d traversal, such as monkey bars and overhanging obstacles.
Yikai Wang retweeted

Manipulation happens through surfaces. To understand contact-rich dexterous interaction, motion alone is not enough. We also need to know surface properties and contact state.
Excited to share ART-Glove, an articulated tactile glove that captures contact-grounded information while preserving human dexterity. It provides:
- Known Geometry: 16 rigid functional surfaces
- Surface Motion: 22 anatomically aligned joints
- Tactile Contact: 2048 piezoresistive taxels
Huge thanks to my advisor Ding @zhao__ding, and to Yuxiang @yxyang1995, Maria @bauzavillalonga, Marissa, and Peide @peide_huang for the valuable advice and discussions.
Paper: arxiv.org/abs/2606.16370
Yikai Wang retweeted

A touch-aware humanoid manipulation policy that cleans the lab for you🧹🧪
Introducing Humanoid Touch Dream: a real-world system for dexterous, contact-rich humanoid loco-manipulation.
Our key idea is simple: the policy predicts future hand forces and tactile latents alongside actions, within a single-stage training framework.
humanoid-touch-dream.github.…
1/7
Yikai Wang retweeted

Excited to share CoVer-VLA—a fully self-supervised action verifier for VLA models and the first work of my PhD! 🤖
We developed a lightweight verifier that assesses VLA action quality by aligning actions with text-visual features. Best of all? It requires zero failure data and scales seamlessly to large robotics datasets.
Beyond verification, CoVer learns aligned action representations via contrastive learning—opening doors for more downstream robotics tasks such as data curation and OOD detection! 🚀
Huge thanks to my amazing collaborators and advisors, and a special shout-out to @prodarhan for the help with PolaRis! Truly an incredible platform.
Please check out more details in the post, and try to CoVer your VLA policy!

Introducing CoVer-VLA💫— a contrastive verifier + hierarchical test-time scaling framework for VLAs!
- Lightweight 1B verifier 🧠
- Outperforms π₀ & π₀.₅ 🦾
- Trained on Bridge & DROID 🤖
Turns out scaling verification > scaling policy learning for VLA alignment!
🧵👇
🌐 Website: cover-vla.github.io
📄 Paper: arxiv.org/abs/2602.12281
🤗 Models: huggingface.co/cover-vla
💻 Code: github.com/cover-vla/cover-v…

Yikai Wang retweeted
You can have the humanoid G1 learn to climb a 80cm box without human reference, and deploy with one lidar elevation mapping.
The learned motions are kinda out of human's range of motion. (at least hard for me!)

apex-humanoid.github.io/
reward engineering + state machine engineering + nice progress-based rewards for reference-free humanoid agile climbing learning.

Introducing APEX — a unified policy for adaptive humanoid traversal across high platforms up to 80 cm (114% leg length).
- Without reference motion, a generalized ratchet progress reward formulation enables learning of a set of adaptive, contact-rich full-body maneuvers.
- Through distillation, we obtain a single context-aware policy that integrates these maneuvers with cyclic locomotion.
- Deployment relies on elevation mapping from a single LiDAR.
The system demonstrates robust adaptation, autonomous skill selection, and smooth multi-skill transitions.
Website: apex-humanoid.github.io/
Paper: arxiv.org/abs/2602.11143
Huge thanks to my co-authors:@lengtx20, @changyi_lin1, @shiqiliu_67, Shir Simon, Bingqing Chen, Jonathan Francis, @zhao__ding. Also grateful to @yxyang1995 for insightful discussions and valuable feedback.
Yikai Wang retweeted
Introducing LocoTouch:
Quadrupedal robots equipped with tactile sensing can now transport unsecured objects — no mounts, no straps.
The tactile policy transfers zero-shot from sim to real.
Core Task-Agnostic Features:
1. High-fidelity contact simulation for distributed tactile sensors
2. Adaptive gait reward for symmetric, frequency-adaptive locomotion
Website: linchangyi1.github.io/LocoTo…
Paper: arxiv.org/abs/2505.23175
Yikai Wang retweeted
We have fully open-sourced LocoMan, including hardware files in SolidWorks format, and code for both simulation and deployment.
github.com/linchangyi1/LocoM…


LocoMan
= Quadrupedal Robot + 2 * Loco-Manipulator
Powered by dual lightweight 3-DoF Loco-Manipulators and the Whole-Body Controller, LocoMan achieves various challenging tasks, such as manipulation in narrow spaces and bimanual-manipulation.
linchangyi1.github.io/LocoMa…
👇👇👇
Yikai Wang retweeted
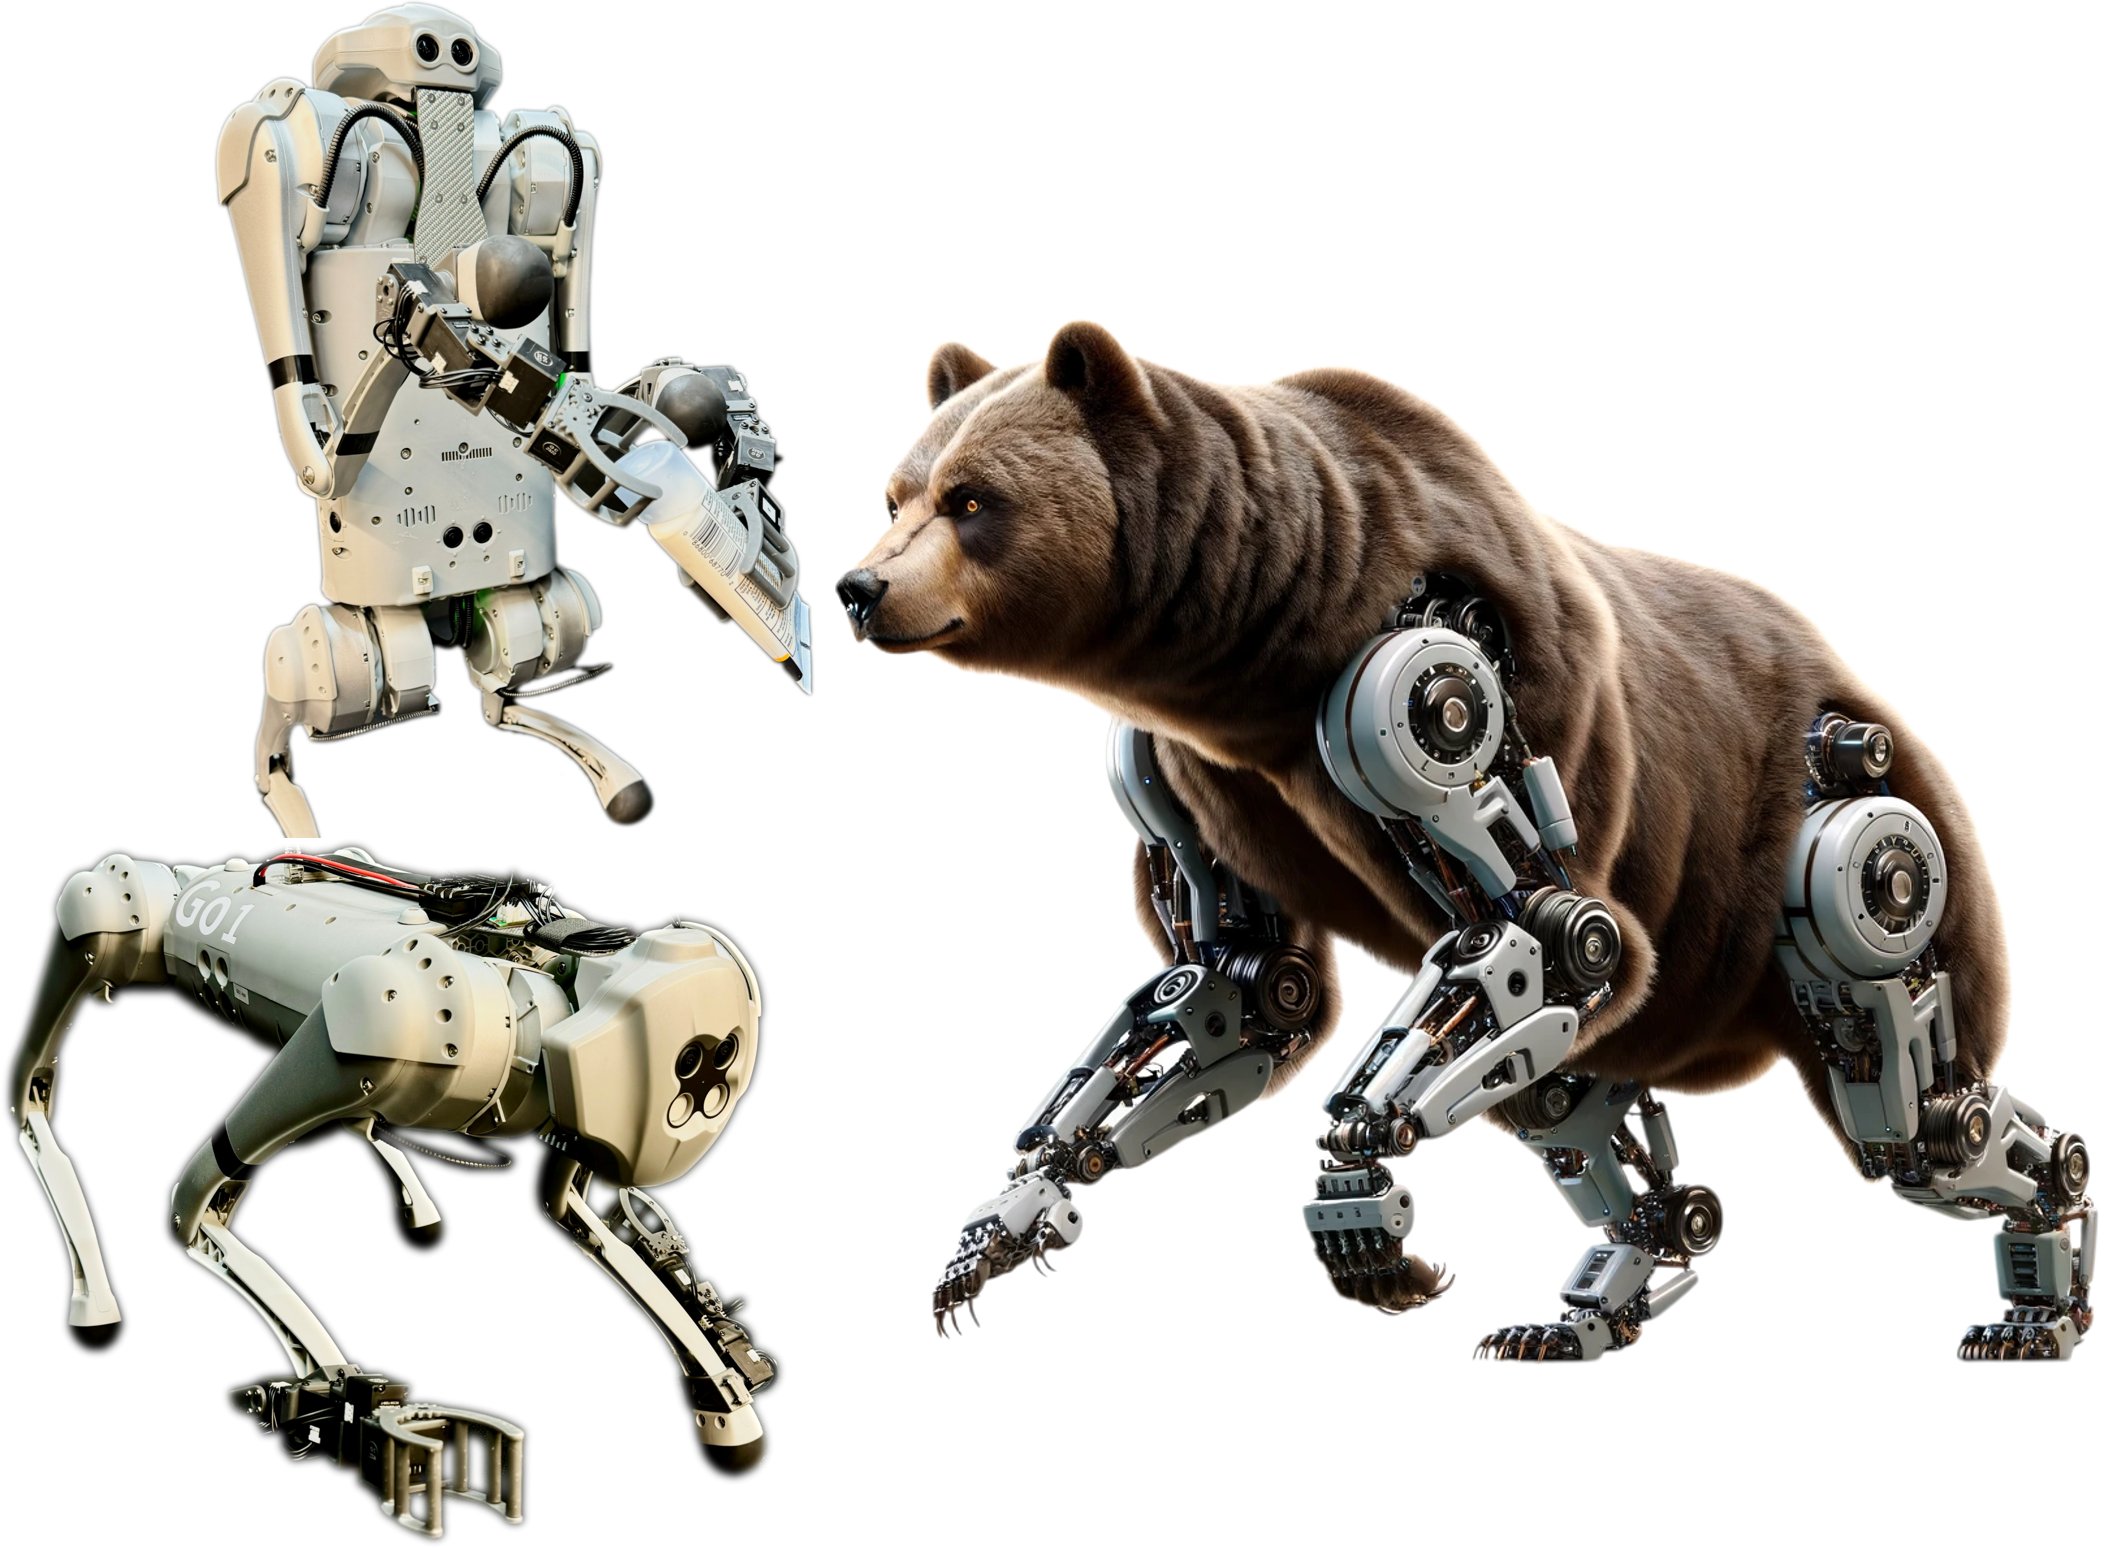
The concept of our loco-manipulators (linchangyi1.github.io/LocoMa…) draws inspiration from the limbs of animals like great apes🦍and bears🐻, which are adept at both locomotion and skilled manipulation. This design enhances the quadrupedal robots’ dexterity for manipulation, while maintaining their agility. Here are some advantages for loco-manipulators vs. top-mounted manipulators:
🐾Loco-manipulators: lightweight, low-cost, compact, natural bimanual manipulation (like a humanoid!), ideal for narrow or low areas
🦾Top-mounted manipulators: more powerful manipulator, larger workspace above the torso, potentially more stable operations (check out the amazing recent work from @xiaolonw's group: wholebody-b1.github.io!)
Which one would be better for loco-manipulation of quadrupedal robots? Loco-manipulators or top-mounted manipulators? Or even a combination of two?🤯One step further, are these quadrupedal transformers more capable/efficient than humanoids in some ways?🤯
Yikai Wang retweeted

🤖 Introducing H2O (Human2HumanOid):
- 🧠 An RL-based human-to-humanoid real-time whole-body teleoperation framework
- 💃 Scalable retargeting and training using large human motion dataset
- 🎥 With just an RGB camera, everyone can teleoperate a full-sized humanoid to perform actions like pick and place, walking, kicking, boxing, etc
- 💡Unleash the potential of humanoids with human cognitive skills and adaptability
🔗: human2humanoid.com
Yikai Wang retweeted

Chinese poems are the best prompts for text-to-image generation! Sincere thanks to #GenerativeAI for visualizing those beautiful verses. Below are some examples by DALLE-3.
东风夜放花千树。更吹落,星如雨。

Recent work!

Quadrupedal robots are mastering agile skills like running, standing, and parkouring, yet face the peril of damaging falls.
Introducing🛡️Guardians as You Fall (GYF), a safe falling and recovery framework that can actively tumble and recover to stable modes to minimize damage in highly dynamic scenarios. Fully open-sourced!
Key idea: Rather than recovering after the robot falls severely, GYF adaptively traverses different stable modes via active tumbling before irrecoverable poses.
Website: sites.google.com/view/guardi…
Code: github.com/ykwang20/Guardian…
Paper: arxiv.org/abs/2310.04828
w/ Yikai Wang, @mengdibellaxu and @zhao__ding